FAST Keypoint detection on excess green images for navigation line extraction in maize fields
Article Sidebar
Main Article Content
Abstract
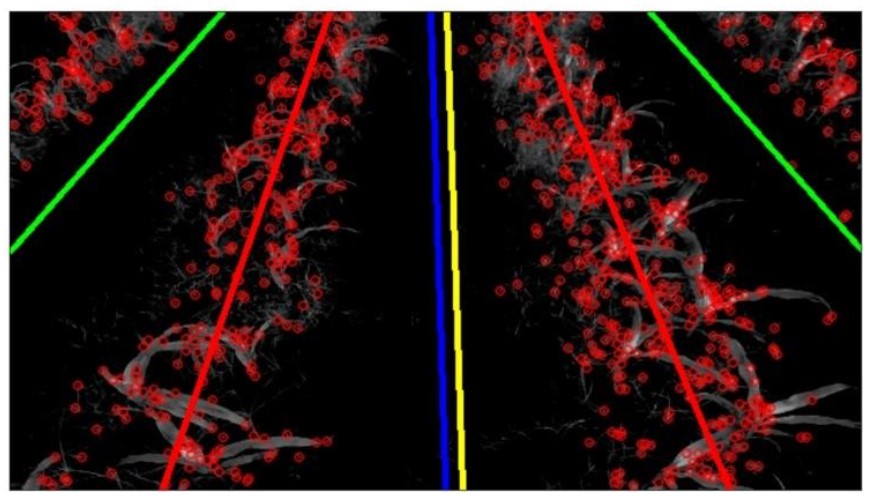
Maize field interrow navigation requires high precision for mobile robot heading control because of the narrow soil area between maize rows. This paper presents a new method for extracting a navigation line in the interrow space of maize fields of an automatic granule fertilizer dispenser (AGFD) robot. The proposed algorithm is a crop row detection approach named FAST keypoint detection, which is applied to the excess green image. The FAST keypoints detected are distributed throughout the crop rows in the image. The crop row lines are fitted by the least squares method. Afterward, the navigation line is extracted. The initial region of interest (ROI) is automatically identified using YOLO-based soil segmentation and the adaptive boundary lines are generated. The RMSE and R2 value of the navigation lines obtained from the proposed method is compared with that of the excess red- and excess green-based methods. The proposed method achieved a minimum RMSE of 10.06 pixels and a maximum R² value of 0.75. The results reveal that the FAST keypoint detection method on the excess green image outperforms the benchmarks methods for various stages of maize growth with respect to both higher accuracy and less computation time. The proposed method achieved a maximum RMSE improvement of 10 pixels (43.74%), reducing the error from 22.86 pixels, while requiring a computational time of only 53 ms, corresponding to 17% of that of the benchmark method. The results of the proposed method under various field conditions, including differences in illumination, soil color, and vegetation density, are also presented. The proposed method is capable of real-time implementation on the AGFD robot.
Article Details

This work is licensed under a Creative Commons Attribution-NonCommercial-NoDerivatives 4.0 International License.

This work is licensed under a Creative Commons Attribution-NonCommercial-NoDerivatives 4.0 International License.
References
Kuan YN, Goh KM, Lim LL. Systematic review on machine learning and computer vision in precision agriculture: applications, trends, and emerging techniques. Eng Appl Artif Intell. 2025;148:110401. DOI: https://doi.org/10.1016/j.engappai.2025.110401
Zhu ZX, Chen J, Yoshida T, Torisu R, Song ZH, Mao ER. Path tracking control of autonomous agricultural mobile robots. J Zhejiang Univ - Sci A. 2007;8:1596-603. DOI: https://doi.org/10.1631/jzus.2007.A1596
Burgos-Artizzu XP, Ribeiro A, Guijarro M, Pajares G. Real-time image processing for crop/weed discrimination in maize fields. Comput Electron Agric. 2011;75(2):337-46. DOI: https://doi.org/10.1016/j.compag.2010.12.011
Ji R, Qi L. Crop-row detection algorithm based on Random Hough Transformation. Math Comput Model. 2011;54(3-4):1016-20. DOI: https://doi.org/10.1016/j.mcm.2010.11.030
Rovira-Más F, Zhang Q, Reid JF, Will JD. Hough-transform-based vision algorithm for crop row detection of an automated agricultural vehicle. Proc Inst Mech Eng D: J Automob Eng. 2005;219(8): 999-1010. DOI: https://doi.org/10.1243/095440705X34667
Bakker T, Wouters H, van Asselt K, Bontsema J, Tang L, Müller J, et al. A vision based row detection system for sugar beet. Comput Electron Agric. 2008;60(1):87-95. DOI: https://doi.org/10.1016/j.compag.2007.07.006
Jiang G, Wang Z, Liu H. Automatic detection of crop rows based on multi-ROIs. Expert Systems With Applications. 2015;42(5): 2429-41. DOI: https://doi.org/10.1016/j.eswa.2014.10.033
Montalvo M, Pajares G, Guerrero JM, Romeo J, Guijarro M, Ribeiro A, et al. Automatic detection of crop rows in maize fields with high weeds pressure. Expert Syst Appl. 2012;39(15):11889-97. DOI: https://doi.org/10.1016/j.eswa.2012.02.117
Bengochea-Guevara JM, Conesa-Muñoz J, Andújar D, Ribeiro A. Merge fuzzy visual servoing and GPS-Based planning to obtain a proper navigation behavior for a small crop-inspection robot. Sensors. 2016;16(3): 276. DOI: https://doi.org/10.3390/s16030276
Liu L, Mei T, Niu R, Wang J, Liu Y, Chu S. RBF-Based monocular vision navigation for small vehicles in narrow space below maize canopy. Appl Sci. 2016;6(6):182. DOI: https://doi.org/10.3390/app6060182
Yang S, Mei S, Zhang Y. Detection of maize navigation centerline based on machine vision. IFAC-Pap. 2018;51(17):570-5. DOI: https://doi.org/10.1016/j.ifacol.2018.08.140
Suriyakoon S, Ruangpayoongsak N. Leading point based interrow robot guidance in corn fields. Proceeding of International Conference on Control and Robotics Engineering(ICCRE); 2017 Apr 1-3; Bangkok, Thailand. USA: IEEE; 2017. DOI: https://doi.org/10.1109/ICCRE.2017.7935032
Zhang X, Li X, Zhang B, Zhou J, Tian G, Xiong Y, et al. Automated robust crop-row detection in maize fields based on position clustering algorithm and shortest path method. Comput Electron Agric. 2018;154:165-75. DOI: https://doi.org/10.1016/j.compag.2018.09.014
Zhou Y, Yang Y, Zhang B, Wen X, Yue X, Chen L. Autonomous detection of crop rows based on adaptive multi-ROI in maize fields. nt J Agric Biol En. 2021;14(4):217-25. DOI: https://doi.org/10.25165/j.ijabe.20211404.6315
Li X, Su J, Yue Z, Duan F. Adaptive Multi-ROI agricultural robot navigation line extraction based on image semantic segmentation. Sensors. 2022;22(20):7707. DOI: https://doi.org/10.3390/s22207707
Affonso F, Tommaselli FAG, Capezzuto G, Gasparino MV, Chowdhary G, Becker M. CROW: a self-supervised crop row navigation algorithm for agricultural fields. J Intell Robot Syst. 2025;111:28. DOI: https://doi.org/10.1007/s10846-025-02219-2
Liang X, Chen B, Wei C, Zhang X. Inter-row navigation line detection for cotton with broken rows. Plant Methods. 2022;18:90. DOI: https://doi.org/10.1186/s13007-022-00913-y
Zheng K, Zhao X, Han C, He Y, Zhai C, Zhao C. Design and experiment of an automatic row-oriented spraying system based on machine vision for early-stage maize corps. Agriculture. 2023;13(3):691. DOI: https://doi.org/10.3390/agriculture13030691
Wei J, Zhang M, Wu C, Ma Q, Wang W, Wan C. Accurate crop row recognition of maize at the seedling stage using lightweight network. Int J Agric Biol Eng. 2024;17(1):189-98. DOI: https://doi.org/10.25165/j.ijabe.20241701.7051
Zhang J, Ma Y, Fan Y, Su N, He X, Zhang H. Real-Time navigation line extraction for cabbage harvesting robots in complex farmland environments: a multi-mask fusion and dynamic row-tracking approach. Int Core J Eng. 2025;11(6):291-304.
Ruangpayoongsak N, Rangdeang T, Puakhom C. Vision-based maize field zone classification for control of robot automatically dispensing granular fertilizer. Agr Nat Resour. 2025;59(6):590605. DOI: https://doi.org/10.34044/j.anres.2025.59.6.05
Guijarro M, Pajares G, Riomoros I, Herrera PJ, Burgos-Artizzu XP, Ribeiro A. Automatic segmentation of relevant textures in agricultural images. Comput Electron Agric. 2011;75(1):75-83. DOI: https://doi.org/10.1016/j.compag.2010.09.013
Rosten E, Drummond T. Machine learning for high-speed corner detection. In: Leonardis A, Bischof H, Pinz A, editors. ECCV 2006. Lecture Notes in Computer Science, vol. 3951. Berlin: Springer; 2006. p. 430-43. DOI: https://doi.org/10.1007/11744023_34
Oliveira H, Vangasse A, Soares L, Oliveira A, Ferreira B, Leite G. An adaptable mobile robot platform with vision-based perception for precision agriculture. Proceeding of 2023 Latin American Robotics Symposium (LARS), 2023 Brazilian Symposium on Robotics (SBR), and 2023 Workshop on Robotics in Education (WRE); 2023 Oct 9-11; Salvador, Brazil. USA: IEEE; 2023. p. 466-71. DOI: https://doi.org/10.1109/LARS/SBR/WRE59448.2023.10333061
Roboflow. Row object detection dataset [Internet]. 2025 [cited 2025 Dec 26]. Available from: https://universe.roboflow.com/tps-klzw4/row-6hskc-qp5g7.
